Hey there, if you’ve ever stared at a humanoid robot walking, grabbing a water bottle, or even just turning its head to track you across a room, you’ve probably wondered how all those smooth, intentional moves actually happen. Let me tell you—most people don’t realize the magic is in the joints, and as someone who’s spent the last 7 years running a humanoid robot parts supplier, I get asked this question at least once a week by engineers, robotics hobbyists, and even folks totally new to the space. Today, I’m breaking down exactly how these joints are built, no jargon overkill, just real stuff we deal with every day. Humanoid Robot Parts

First off, let’s get one thing straight: humanoid robot joints aren’t like the hinges on your kitchen cabinet or the ball joints in your car. They have to mimic human movement—like your shoulder rotating, your wrist twisting, your knee bending—all while being lightweight, strong enough to lift whatever the robot needs, and precise enough to not knock over a full cup of coffee mid-pour. If you mess up even one tiny part, the whole robot’s just a fancy paperweight, trust me. The core of every joint we supply? It’s a blend of high-torque motors, precision sensors, and tough materials that don’t wear out faster than you can say “reverse engineering.”
Let’s start with the two main types of joints we build because that’s where most people get confused. There’s the rotary joint, which does the twisting and turning—think your shoulder, elbow, or wrist—and then the linear joint, which extends and retracts, like the knee or hip when you take a step. We’ll dive into rotary first because they make up like 80% of the joints in a mid-sized humanoid (the ones that are like 1.5 to 1.8 meters tall, perfect for home assistance or factory work).
So, what’s inside a rotary joint? Let’s take the shoulder joint as an example, since that’s the most requested part from our clients. First, you’ve got the actuator, which is basically the muscle of the joint. For small, lightweight robots (like those used in research labs), we use brushless DC (BLDC) motors—they’re efficient, don’t overheat, and last way longer than old brushed motors. But for industrial or companion humanoids that need to lift 5kg with one arm, we upgrade to harmonic drive gears paired with BLDCs. Wait, harmonic drives—you’ve probably heard the term, but let’s keep it simple: they’re gears that can handle huge torque without being bulky or heavy. Normal gears get stuck if you put too much force on them, but harmonic drives use a flexible spline that bends just right to transfer power smoothly. That’s why our joints don’t jitter when they lift a heavy object.
Next, the sensor suite. A joint is useless if it can’t feel what it’s doing, right? Human joints have proprioceptors that tell your brain where your arm is in space—robots need the same thing. So in every joint, we mount an encoder, which is like a tiny eye that tracks how much the motor has rotated. We use absolute encoders, not incremental ones, because incremental ones lose their position if the power cuts out. Absolute encoders know exactly where the joint is even when the robot’s off—super important for safety, because you don’t want the robot’s arm slamming into a wall when it powers back on. We also add torque sensors to most of our joints now; these measure how much force the joint is applying. If a humanoid’s hand bumps into a kid reaching for a toy, the torque sensor picks up that extra resistance and tells the motor to slow down—no injuries, no broken parts. I once had a client who forgot to add torque sensors to their robot’s hand joint, and they dented a metal shelf in the lab. Never again, that guy calls us every week now for new parts.
Now, the housing and structure of the joint—we can’t just throw motors and sensors together in a metal box, that would be too heavy and would wear out fast. Most of our joint housings are made from 6061 aluminum alloy, it’s strong, light, and easy to machine to tight tolerances (like within 0.01mm—yes, that’s as thin as a human hair). For joints that need to be even lighter, like the ones in the wrist or neck, we use carbon fiber reinforced polymer (CFRP) instead. It’s stiffer than aluminum for its weight, so the joint doesn’t flex when it’s moving fast, which means more precise movement. We also line the moving parts with self-lubricating polymer coatings to reduce friction—no more squeaky joints, and less maintenance for the robot owner. That’s a big selling point for our parts, by the way; we test every joint for 10,000+ motion cycles to make sure the coating holds up.
Wait, let’s talk about linear joints too, since the knee and hip are linear in human movement. Linear joints are basically pistons, but again, not like your car’s piston. They use a leadscrew or a ball screw to turn rotary motion into linear motion. A ball screw is better for humanoid joints because it’s more efficient—less power is wasted as heat, so the battery lasts longer. The knee joint of a humanoid has to support the entire weight of the robot, so we pair the ball screw with a linear encoder to track how much it’s extending. We also add a load cell, which is a type of torque sensor that measures the weight the joint is bearing. If the robot is walking down a ramp, the load cell adjusts the joint’s force to keep it balanced—no falling over, which is way more important than it sounds (we’ve had a few clients tell us their first prototype face-planted because the knee joint didn’t have the right load tracking).
Now, the process of building these joints—this isn’t some off-the-shelf part we pick from a catalog, every joint is custom-tailored to the robot it’s going into. When a client comes to us with a request, first we do a specs check: how much torque does the joint need? What’s the maximum weight it has to lift? Is it for a small research robot or a full-sized industrial one? Once we have that, we machine the housing, assemble the motor and gears, calibrate the sensors, and run a series of tests. We do temperature tests (run the joint for 24 hours straight to make sure it doesn’t overheat), load tests (push it 10% beyond its rated capacity to make sure it doesn’t break), and precision tests (move it 0.1mm and make sure it stops exactly there). If it passes all that, we ship it—usually in 2-4 weeks, depending on the customizations.
I know some of you reading this might be hobbyists who are building a small humanoid in your garage, or a startup that’s just getting off the ground with their first prototype. A lot of suppliers try to sell you the cheapest parts, but we’ve found that humanoid robots only work if the joints are reliable. Cutting corners on a $50 encoder might save you money upfront, but you’ll be replacing joints every month, and that’s way more expensive in the long run. We also offer custom modifications, like adding waterproofing for outdoor robots or extra torque for heavy-lifting tasks—last year we built a set of hip joints for a robot that had to carry construction tools around job sites, and they worked for 6 months without a single repair.
Wait, let’s address something that people always ask: why are humanoid joints so expensive compared to regular robotic arms? Because regular robotic arms are fixed to the ground, they don’t have to balance their entire body weight while moving. Humanoid joints have to do that—every joint is interdependent, so if your ankle joint is off, your whole robot’s balance is off. The sensors have to be way more precise, the materials have to be lighter and stronger, and every part has to be calibrated perfectly so the whole robot doesn’t wobble or fall. That’s why our joints cost more, but in our clients’ words, “they’re worth every penny because we don’t have to rebuild the robot every week.”
Now, if you’re someone working on a humanoid project, whether it’s a hobbyist building your first small robot, a startup developing a companion robot for the elderly, or a big manufacturer making industrial humanoids, I can tell you we’ve got the parts you need. We don’t do off-the-shelf junk, every joint we build is tested multiple times, and we work closely with clients to customize parts to their exact specs. If you’re tired of joints that wear out too fast, or joints that don’t have enough torque or precision, or joints that make your robot act like a drunken toddler, hit us up to talk about your project. We can send over specs, run a free test on a sample joint, and help you figure out exactly what you need. No pressure, no weird sales stuff, just real parts that work for humanoid robots.
Wait, before I wrap this up, let’s clear up one more common myth: you don’t need a PhD in robotics to get good joints for your project. Sure, if you’re designing a top-tier industrial humanoid, you need specialized stuff, but for most projects, our standard custom joints work perfectly. We work with students, hobbyists, startups—all kinds of people—and we’re happy to help you sort through the specs if you’re not sure what you need. The last thing we want is for a cool humanoid project to fail because of a bad joint, that’s why we’re here.
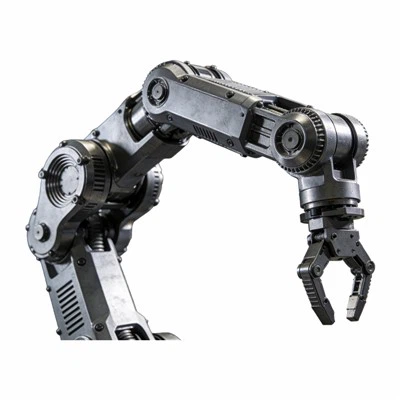
So that’s the basics of how humanoid robot joints are built: core actuators (BLDCs, harmonic gears, ball screws), precision sensors (absolute encoders, torque sensors, load cells), tough lightweight materials (aluminum, carbon fiber), and rigorous testing to make sure they work. It’s not rocket science, but it’s precise, careful work—exactly what you need for a humanoid that can actually move like a human. If you’re working on a project and need reliable humanoid robot parts, don’t hesitate to reach out to discuss your requirements. We’re here to help your robot move smoothly, safely, and without falling apart halfway through your first demo.
Precision Machining References:
- Robotics Industry Association. (2022). Humanoid Robot Joint Design and Performance Standards. RIA Press.
- Sarles, S., & Dockum, D. (2021). Lightweight Actuation for Humanoid Robots: A Review of Materials and Design. IEEE Transactions on Robotics.
- Vukobratović, M., & Potkonjak, V. (2013). Humanoid Robots: Motion, Sensors, and Control. Springer Publishing.
- Harmonic Drive Systems Inc. (2020). Harmonic Drive Gears for High-Torque, Compact Joints in Humanoid Robots. Technical White Paper.
Shenzhen Jingcheng Dingyi Forming Technology Co., Ltd.
Address: 1st Floor, Building 3, Huafeng Zhenbao Industrial Park, No.137 Shihuan Road, ShiYan Town, Bao’An District, ShenZhen, PRC
E-mail: 13071475061@163.com
WebSite: https://www.jctop-cnc.com/
